We develop computer vision and XR systems that help people who are blind or have low vision navigate and understand real-world environments.
Apurv Varshney
PhD StudentCS
Apurv Varshney is a PhD student in Computer Science at UC Santa Barbara. He develops computer vision and interactive systems that help people navigate complex environments more effectively.
His research sits at the intersection of computer vision, human-computer interaction, and extended reality. His dissertation focuses on the “last mile” of navigation for people who are blind or have low vision, including how wearable cameras can capture useful spatial information and how that information should be translated into intuitive guidance. More broadly, he studies how sensing, scene understanding, and interface design can work together to support real-time movement and decision-making.
Apurv earned his B.Tech. in Computer Science from the Indian Institute of Technology Goa. He began graduate study at UC Santa Barbara in the M.S. program in 2021 and joined the Bionic Vision Lab later that year as a graduate researcher before transitioning into the PhD program. He now leads development of the lab’s BionicVisionXR platform for building and evaluating immersive visual-assistance systems, and received the UC Santa Barbara Computer Science Outstanding TA Award in 2025.
Outside of the lab, Apurv enjoys biking and playing tennis.
Education
- PhD in Computer Science UC Santa Barbara2023–2027 (expected)
- BTech (Bachelors of Technology) in Computer Science Indian Institute of Technology (IIT), Goa2020
Honors & Awards
- Outstanding TA Award Computer Science, UC Santa Barbara (2025)
Research Areas
Affiliated Research Areas
Navigation, Attention & Individual Differences
We use immersive VR, eye tracking, and mobile EEG to study how people navigate complex environments, how they use navigation aids, and why strategies and performance differ across individuals.
Software
BionicVisionXR: An Open-Source Virtual Reality Toolbox for Bionic Vision
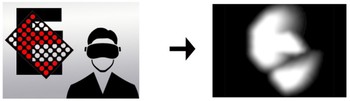
BionicVisionXR is an open-source virtual reality toolbox for studying simulated prosthetic vision during natural head and body movement.
Publications
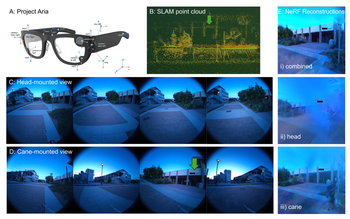
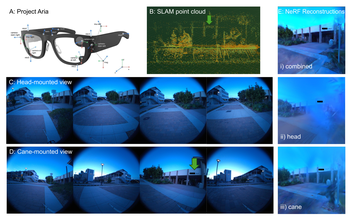
Navigating the last mile: Evaluating head- and cane-mounted cameras for egocentric spatial awareness
We evaluate head- and cane-mounted cameras for blind navigation and show that combining both yields superior spatial perception, guiding the design of hybrid, user-aligned assistive systems.
 Apurv Varshney
 Lucas Nadolskis
 Tobias Höllerer
 Michael Beyeler
25th IEEE International Symposium on Mixed and Augmented Reality (ISMAR)
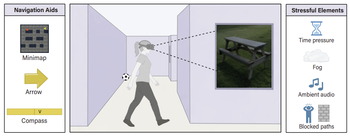
Actionable guidance outperforms map and compass cues in demanding immersive VR wayfinding
We compared three common guidance techniques for immersive VR wayfinding: a directional arrow, a minimap, and a compass.
Apurv Varshney  Lily M. Turkstra
 Jiaxin Su Mable Zhou
 Scott T. Grafton
 Barry Giesbrecht
 Mary Hegarty Michael Beyeler
IEEE Transactions on Visualization and Computer Graphics (TVCG) Special Issue on the 25th IEEE International Symposium on Mixed and Augmented Reality (ISMAR)
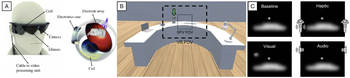
Cross-modal guidance for out-of-view object search in simulated prosthetic vision
We compared visual, auditory, and haptic out-of-view guidance during object search under simulated prosthetic vision, and found that the non-visual cues supported faster search than a visual cue competing for the same sparse phosphene bandwidth.
 Adyah Rastogi Apurv Varshney Tobias Höllerer Michael Beyeler
arXiv:2609.01438
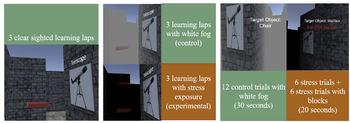
Adaptive training for navigation under stress: Impacts of stress exposure and spatial anxiety
We examine whether stress exposure during environmental learning fosters resilience to stress in subsequent navigation or impairs learning.
Mable Zhou Apurv Varshney Kayla P. Salcedo Scott T. Grafton Barry Giesbrecht Michael Beyeler Mary Hegarty
PsyArxiv
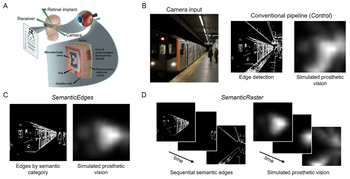
Static or temporal? Semantic scene simplification to aid wayfinding in immersive simulations of bionic vision
We compare two complementary approaches to semantic preprocessing in immersive virtual reality: SemanticEdges, which highlights all relevant objects at once, and SemanticRaster, which staggers object categories over time to reduce visual clutter.
 Justin M. Kasowski Apurv Varshney Michael Beyeler
31st ACM Symposium on Virtual Reality Software and Technology (VRST) ‘25
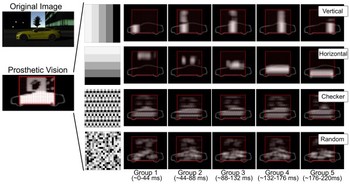
Simulated prosthetic vision confirms checkerboard as an effective raster pattern for epiretinal implants
Using an immersive VR system, we systematically evaluated two behavioral tasks under four raster patterns (horizontal, vertical, checkerboard, and random) and found checkerboard raster to be the most effective.
Justin M. Kasowski Apurv Varshney  Roksana Sadeghi Michael Beyeler
Journal of Neural Engineering 22 046017
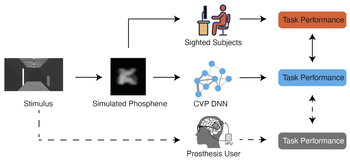
A deep learning framework for predicting functional visual performance in bionic eye users
We introduce a computational virtual patient (CVP) pipeline that integrates anatomically grounded phosphene simulation with task-optimized deep neural networks to forecast patient perceptual capabilities across diverse prosthetic designs and tasks.
Jonathan Skaza Shravan Murlidaran Apurv Varshney Ziqi Wen William Y. Wang  Miguel P. Eckstein Michael Beyeler
bioRxiv
Stress affects navigation strategies in immersive virtual reality
We used immersive virtual reality to develop a novel behavioral paradigm to examine navigation under dynamically changing, high-stress situations.
Apurv Varshney Mitchell Munns Justin M. Kasowski Mantong Zhou Chuanxiuyue He Scott T. Grafton Barry Giesbrecht Mary Hegarty Michael Beyeler
Scientific Reports