We develop computer vision and XR systems that help people who are blind or have low vision navigate and understand real-world environments.
Open-source software
BionicVisionXR: An Open-Source Virtual Reality Toolbox for Bionic Vision
In Brief
BionicVisionXR is an open-source virtual reality toolbox for studying simulated prosthetic vision during natural head and body movement.
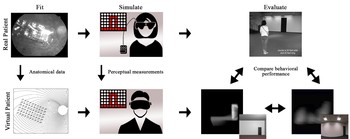
BionicVisionXR is an open-source toolbox for simulating visual prostheses in immersive virtual reality. It lets sighted participants experience model-based approximations of prosthetic vision while freely moving through virtual environments.
VR is especially useful for prosthetic vision because current implants provide only a small field of view, forcing users to scan the environment with head and body movements. Those behaviors are difficult to reproduce with conventional screen-based simulations.
BionicVisionXR combines immersive environments with computational models of prosthetic vision, allowing researchers to study navigation, object search, scene understanding, and other visually guided behaviors under controlled conditions. The toolbox is designed for experiments that need both realistic movement and biologically informed models of what an implant may produce.
Team
Affiliate
Principal Investigator
Research Areas
Human Adaptation to Vision Loss & Restoration Recruiting
We study how people adapt to vision loss and restored sight, and how training, rehabilitation, and better outcome measures can improve everyday visual function.

Publications
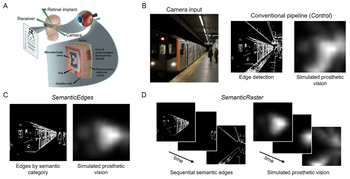
Static or temporal? Semantic scene simplification to aid wayfinding in immersive simulations of bionic vision
We compare two complementary approaches to semantic preprocessing in immersive virtual reality: SemanticEdges, which highlights all relevant objects at once, and SemanticRaster, which staggers object categories over time to reduce visual clutter.
 Justin M. Kasowski
 Apurv Varshney
 Michael Beyeler
31st ACM Symposium on Virtual Reality Software and Technology (VRST) ‘25
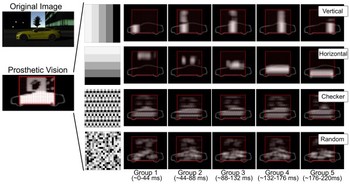
Simulated prosthetic vision confirms checkerboard as an effective raster pattern for epiretinal implants
Using an immersive VR system, we systematically evaluated two behavioral tasks under four raster patterns (horizontal, vertical, checkerboard, and random) and found checkerboard raster to be the most effective.
Justin M. Kasowski Apurv Varshney  Roksana Sadeghi Michael Beyeler
Journal of Neural Engineering 22 046017
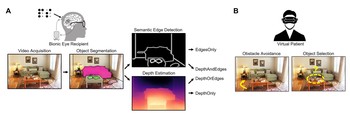
The relative importance of depth cues and semantic edges for indoor mobility using simulated prosthetic vision in immersive virtual reality
We used a neurobiologically inspired model of simulated prosthetic vision in an immersive virtual reality environment to test the relative importance of semantic edges and relative depth cues to support the ability to avoid obstacles and identify objects.
 Alex Rasla Michael Beyeler
28th ACM Symposium on Virtual Reality Software and Technology (VRST) ‘22
Immersive virtual reality simulations of bionic vision
We present VR-SPV, an open-source virtual reality toolbox for simulated prosthetic vision that uses a psychophysically validated computational model to allow sighted participants to ‘see through the eyes’ of a bionic eye user.
Justin M. Kasowski Michael Beyeler
ACM Augmented Humans (AHs) ‘22
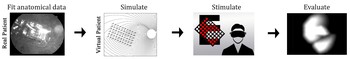
Towards immersive virtual reality simulations of bionic vision
We propose to embed biologically realistic models of simulated prosthetic vision in immersive virtual reality so that sighted subjects can act as ‘virtual patients’ in real-world tasks.
Justin M. Kasowski  Nathan Wu Michael Beyeler
ACM Augmented Humans (AHs) ‘21